HPS GSRD User Guide
Overview
This page presents the HPS Baseline System Example Design (formerly known as "GSRD" or "Golden System Reference Design") for the Agilex™ 7 FPGA M-Series Development Kit - HBM2e Edition (3x F-Tile & 1x R-Tile) ES.
- Quartus Design
- LEDs connected to GPIO soft IP modules
- DIP switches and push buttons connected to GPIO soft IP modules
- HPS Software
- Linux, booted by U-Boot
- Board web server
- Sample driver
- Reacting to FPGA DIP switches and push buttons
- Sample applications
- Hello world
- Controlling FPGA LEDs: blink, scroll, toggle
- System check application
Prerequisites
The following are required in order to be able to fully exercise the System Example Design:
- Agilex™ 7 FPGA M-Series Development Kit - HBM2e Edition (3x F-Tile & 1x R-Tile) ES, ordering code DK-DEV-AGM039FES
- SD/MMC HPS Daughtercard
- Mini USB cable for serial output
- Micro USB cable for on-board Intel FPGA Download Cable II
- Micro SD card (4GB or greater)
- Host PC with
- Linux - Ubuntu 22.04LTS was used to create this page, other versions and distributions may work too
- Serial terminal (for example Minicom on Linux and TeraTerm or PuTTY on Windows)
- Micro SD card slot or Micro SD card writer/reader
- Altera® Quartus® Prime Pro Edition Version 26.3
- Local Ethernet network, with DHCP server (will be used to provide IP address to the board)
This page covers the DK-DEV-AGM039FES version of the board. You can identify your board type by looking at the serial number identifier, as shown below:
| Development Kit Version | Ordering Code | Device Part Number | Serial Number Identifier |
|---|---|---|---|
| Agilex™ 7 FPGA M-Series Development Kit - HBM2e Edition (3x F-Tile and 1x R-Tile) | DK-DEV-AGM039FES | AGMF039R47A1E1VC | AGM82DK0001001 |
| Agilex™ 7 FPGA M-Series Development Kit - HBM2e Edition (3x F-Tile and 1x R-Tile) ES1 | DK-DEV-AGM039FES | AGMF039R47A1E2VR0 | AGM82DK0000001 |
The main difference between the boards, in addition to the FPGA part number, is that they use different memory type for HPS:
- DK-DEV-AGM039FES uses HBM memory for HPS
- DK-DEV-AGM039FES uses DDR5 memory for HPS
The U-Boot and Linux compilation, Yocto compilation and creating the SD card image require a Linux host PC. The rest of the operations can be performed on either a Windows or Linux host PC.
Release Notes
The Intel FPGA HPS Embedded Software release notes can be accessed from the following link: https://github.com/altera-fpga/gsrd-socfpga/releases/tag/QPDS26.3_REL_BASELINE_PR
Binary Release Contents
The binary release files are accessible at https://releases.rocketboards.org/2026.10/gsrd/agilex7_dk_dev_agm039fes_gsrd/.
The source code is also included on the SD card in the Linux rootfs path /home/root:
| File | Description |
|---|---|
| linux-socfpga-v6.18.37-lts-src.tar.gz | Source code for Linux kernel |
| u-boot-socfpga-v2026.07-src.tar.gz | Source code for U-Boot |
| arm-trusted-firmware-v2.15.0-src.tar.gz | Source code for Arm Trusted Firmware |
Component Versions
Altera® Quartus® Prime Pro Edition Version 26.3 and the following software component versions integrate the 26.3 release.
| Component | Location | Branch | Commit ID/Tag |
|---|---|---|---|
| HPS Baseline System Example Design | https://github.com/altera-fpga/agilex7-ed-hps-baseline | main | QPDS26.3_REL_BASELINE_PR |
| Linux | https://github.com/altera-fpga/linux-socfpga | socfpga-6.18.37-lts | QPDS26.3_REL_BASELINE_PR |
| Arm Trusted Firmware | https://github.com/altera-fpga/arm-trusted-firmware | socfpga_v2.15.0 | QPDS26.3_REL_BASELINE_PR |
| U-Boot | https://github.com/altera-fpga/u-boot-socfpga | socfpga_v2026.07 | QPDS26.3_REL_BASELINE_PR |
| Yocto Project | https://git.yoctoproject.org/poky | wrynose | latest |
| Yocto meta-altera-fpga Layer | https://github.com/altera-fpga/meta-altera-fpga | wrynose | QPDS26.3_REL_BASELINE_PR |
| KAS | https://github.com/siemens/kas/ | master | 5.4 |
Note: The combination of the component versions indicated in the table above has been validated through the use cases described in this page and it is strongly recommended to use these versions together. If you decided to use any component with different version than the indicated, there is not warranty that this will work.
Note: Starting from 26.3 Quartus release, the build of the Quartus projects in the System Example Designs are based only on Visual Designer Studio (VDS).
Please review the following KDB if you face Quartus design build problems when the RTL was generated with VDS:
Why do Quartus® Prime Pro 26.3 and earlier fail to build a Agilex® 5/Agilex® 3/Agilex® 7 FPGA M-Series VDS based design whose RTL has been generated with VDS?.
Development Kit
The Agilex™ 7 M-Series HBM Development Kit is shown below:
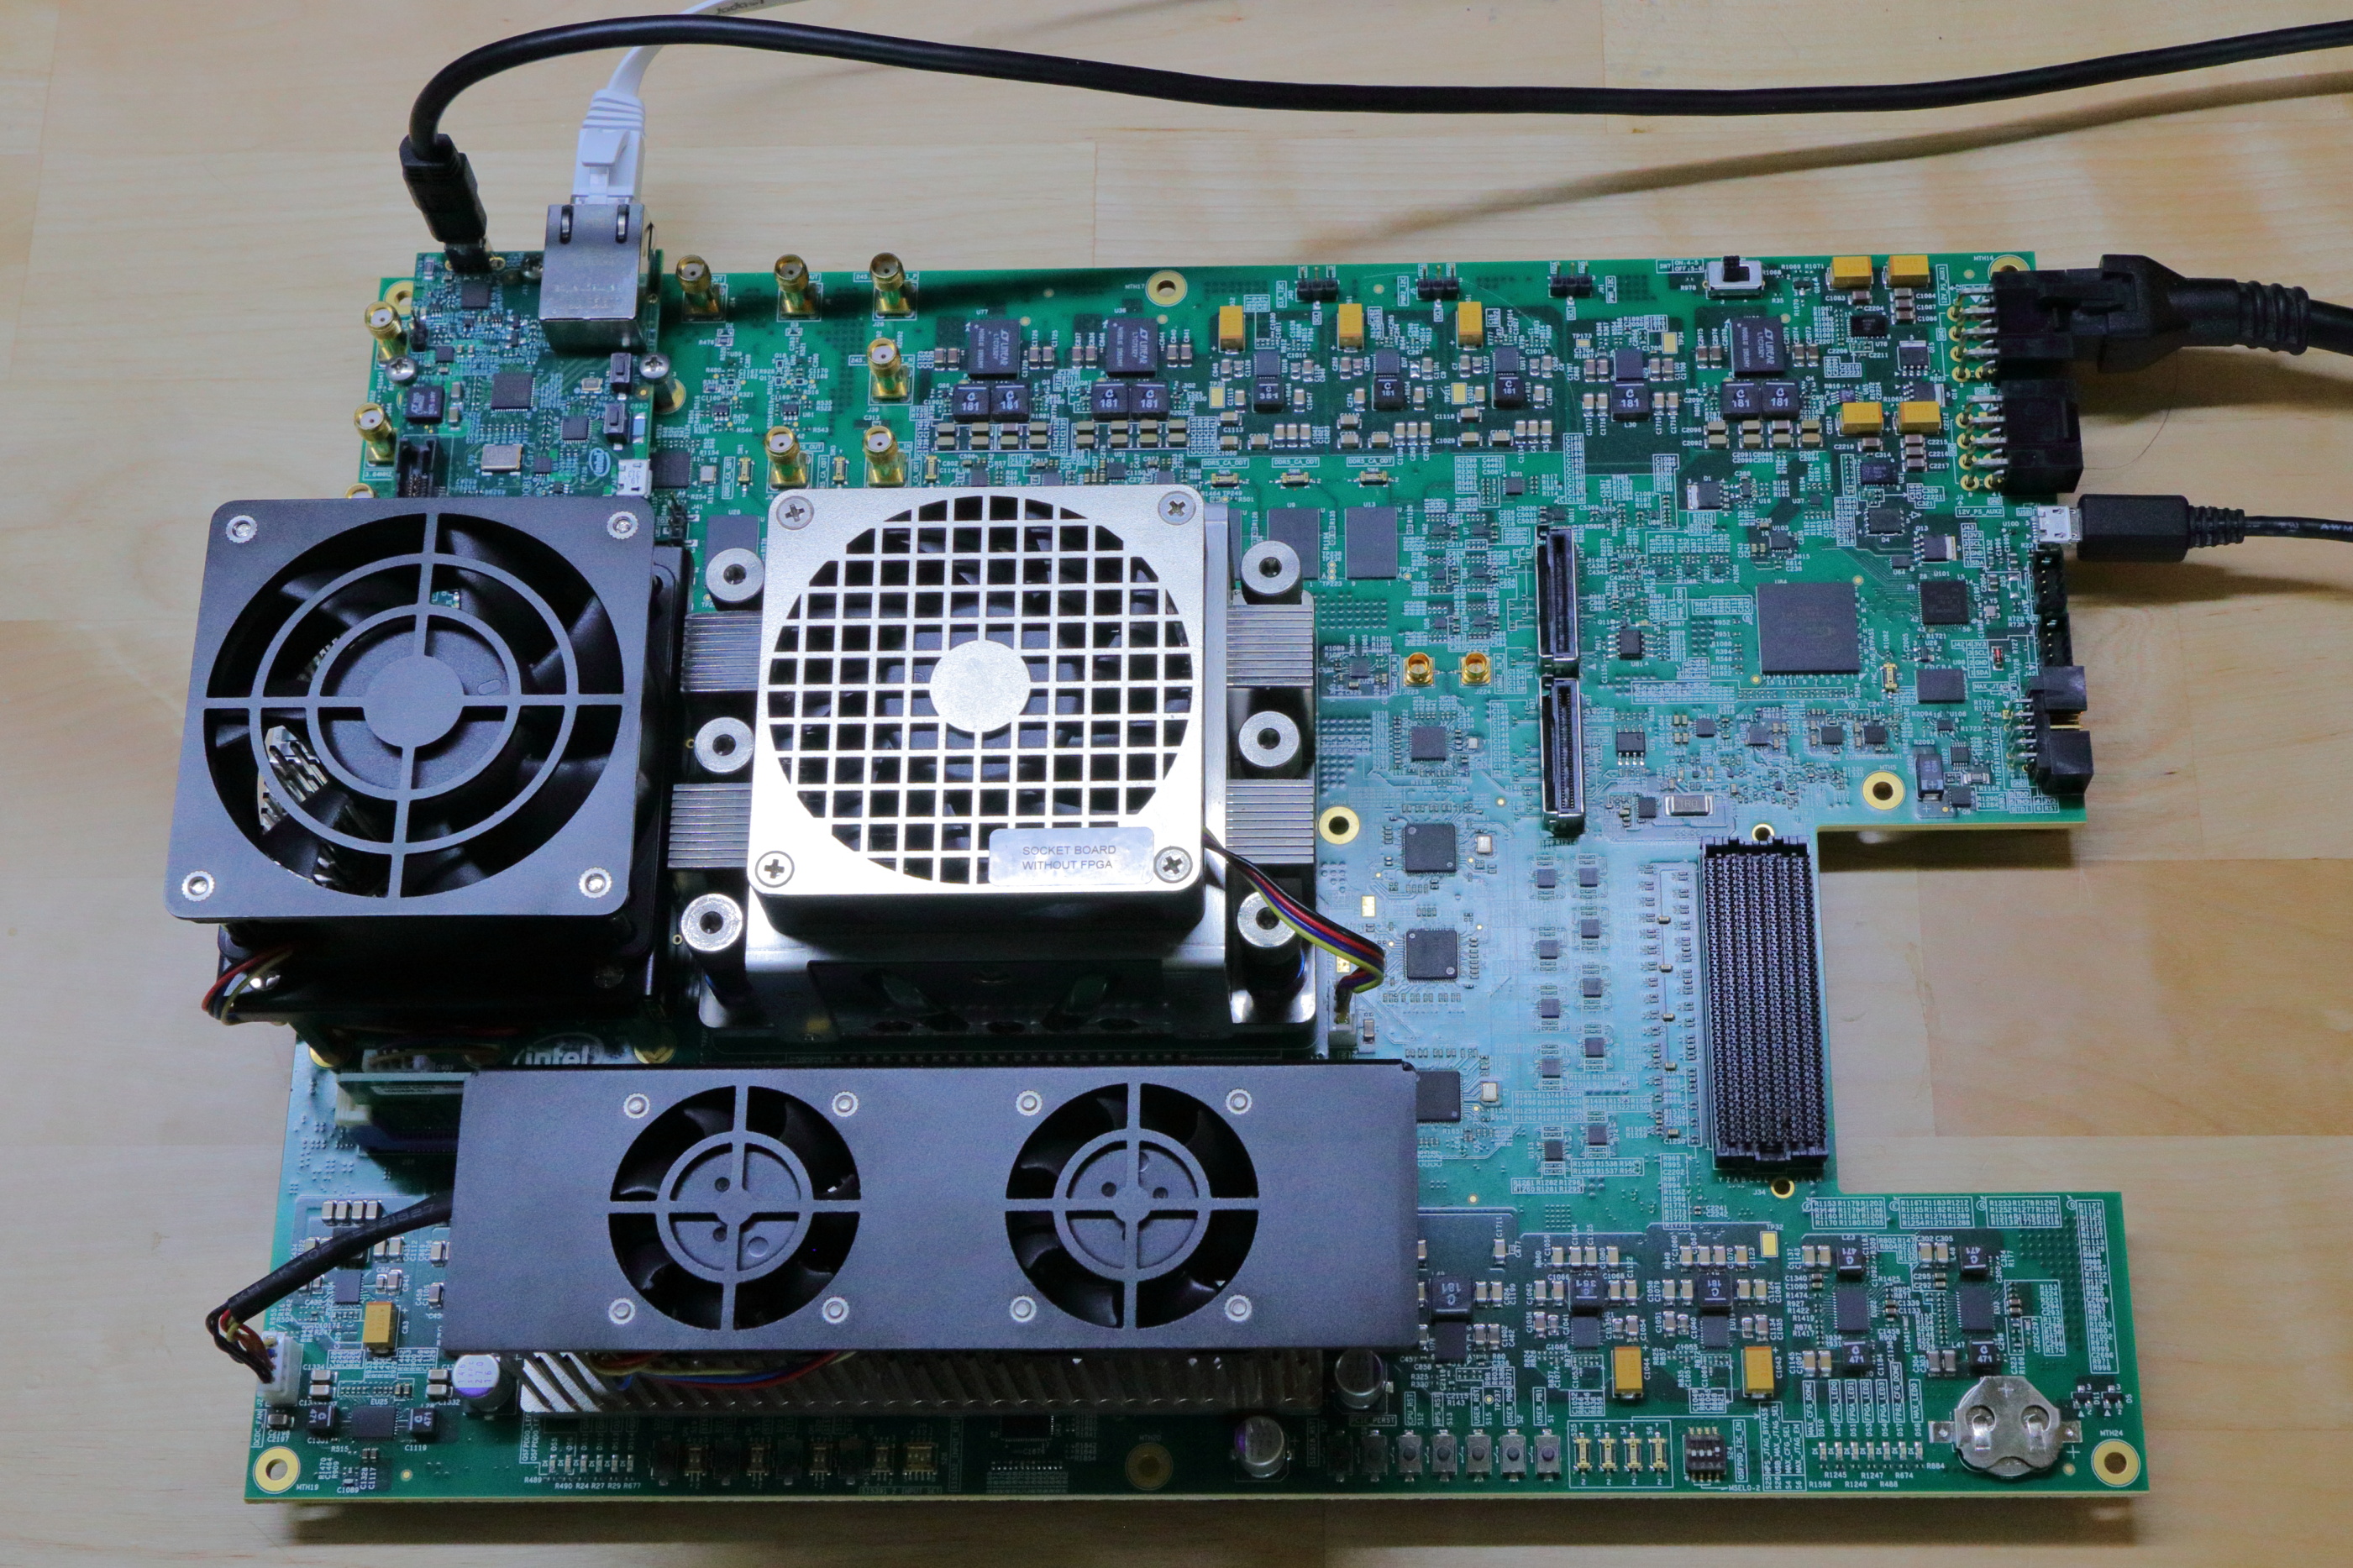
Refer to the following for more information about the Development Kit: https://www.altera.com/products/devkit/po-3016/agilex-7-fpga-m-series-development-kit-hbm2e-edition-3x-f-tile-1x-r-tile-es.
Exercise Prebuilt Binaries
Boot Linux
1. Connect the following cables to the board:
- Power: from board to power supply
- HPS UART Console: from vertical mini USB connector on the HPS daughtercard to host PC
- JTAG: from micro USB cable on edge of the board to host PC
2. Download, extract and write to SD card the following SD card image: https://releases.rocketboards.org/2026.10/gsrd/agilex7_dk_dev_agm039fes_gsrd/sdimage.tar.gz. Note the extracted file name is gsrd-console-image-agilex7m.rootfs.wic.
Then insert SD card into the HPS OOBE Daughtercard socket.
3. Configure board to the default settings, making sure set S24 dipswitch to OFF-OFF-OFF-ON, to select MSEL=JTAG, so that board does not configure on power up.
4. Power up the board
5. Download the HPS RBF file and configure the HPS RBF file over JTAG:
wget https://releases.rocketboards.org/2026.10/gsrd/agilex7_dk_dev_agm039fes_gsrd/ghrd.hps.rbf
quartus_pgm -c 1 -m jtag -o "p;ghrd.hps.rbf"
6. Linux will boot, use 'root' as username to log in, no password will be required.
Run Hello World Application
Change to IntelFPGA folder, and run the hello application, which will display a meesage as shown below:
root@agilex7dkdevagm039:~# cd alteraFPGA/
root@agilex7dkdevagm039:~/alteraFPGA# ./hello
Hello SoC FPGA!
Run SysCheck Application
Run the SysCheck application:
It will display some system information:
 ALTERA SYSTEM CHECK

lo : 127.0.0.1 usb1 : DWC OTG Controller
eth0 : 192.168.1.52
 serial@ffc02100 : disabled
hps_led2 : OFF serial@ffc02000 : okay
hps_led0 : OFF
hps_led1 : OFF
Press Q to exit the appplication.
Connect to Web Server
1. Boot Linux as described in previous section.
2. Determine the IP address of the board using 'ifconfig' as shown above. Note there will be network interfaces of them, either can be used.
3. Open a web browser on the host PC and type http:// on the address box, then type the IP of your board and hit Enter.
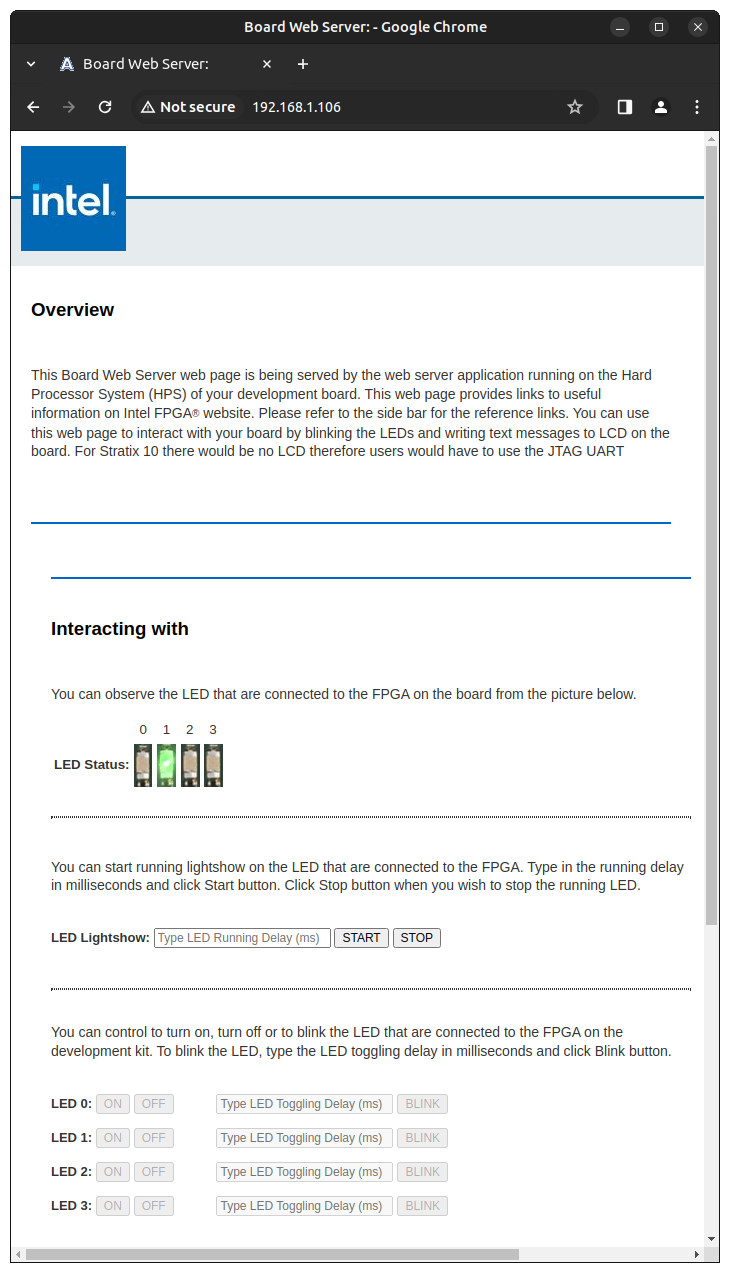
Caution: The web server is intended to allow users to control FPGA connected LEDs on the board. Due to an issue in this release, this functionality is not yet enabled. It will be enabled in the next release.
Connect over SSH
1. The lower bottom of the web page presents instructions on how to connect to the board using an SSH connection.
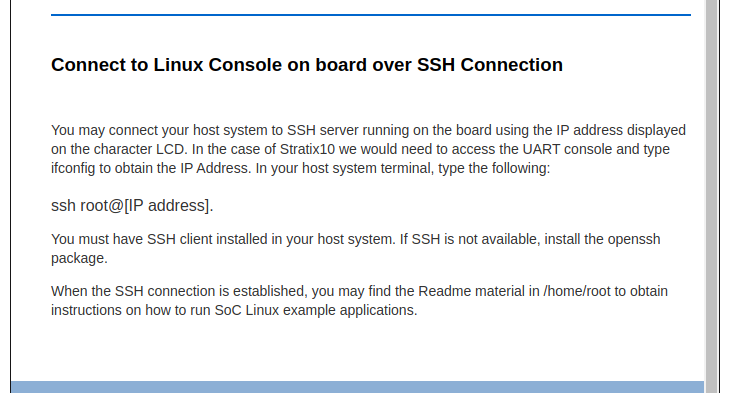
2. If the SSH client is not installed on your host computer, you can install it by running the following command on CentOS:
or the following command on Ubuntu:
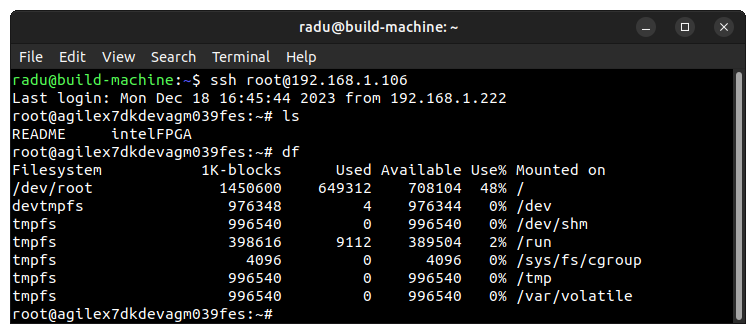
3. Connect to the board, and run some commands, such as pwd, ls and uname to see Linux in action:
Rebuild the System Example Design
The embedded software for this System Example Design is built with Yocto, using KAS.
Kas is a Python-based lightweight build orchestration layer on top of BitBake/Yocto. Kas allows you to define your build environment in a YAML manifest, so you can perform checkout, environment setup, configuration, and build invocation with a single command. Kas provides a more maintainable build description, it offers improved reproducibility, reduced setup friction, and a clearer abstraction for managing multiple layers, revisions, and configuration fragments.
The software source code for this System Example Design is released inside the software/yocto_linux directory. Accessing the link will display a README page with details regarding the software.
For more details about Kas, refer to the official documentation at https://kas.readthedocs.io/en/latest/.
Kas Build Prerequisites
Firtst, the same prerequisites as for regular Yocto build are required.
1. Make sure you have Yocto system requirements met: https://docs.yoctoproject.org/scarthgap/ref-manual/system-requirements.html#supported-linux-distributions.
The command to install the required packages on Ubuntu 22.04 is:
sudo apt-get update
sudo apt-get upgrade
sudo apt-get install openssh-server mc libgmp3-dev libmpc-dev gawk wget git diffstat unzip texinfo gcc \
build-essential chrpath socat cpio python3 python3-pip python3-pexpect xz-utils debianutils iputils-ping \
python3-git python3-jinja2 libegl1-mesa libsdl1.2-dev pylint xterm python3-subunit mesa-common-dev zstd \
liblz4-tool git fakeroot build-essential ncurses-dev xz-utils libssl-dev bc flex libelf-dev bison xinetd \
tftpd tftp nfs-kernel-server libncurses5 libc6-i386 libstdc++6:i386 libgcc++1:i386 lib32z1 \
device-tree-compiler curl mtd-utils u-boot-tools net-tools swig -y
On Ubuntu 22.04 you will also need to point the /bin/sh to /bin/bash, as the default is a link to /bin/dash:
Note: You can also use a Docker container to build the Yocto recipes, refer to https://rocketboards.org/foswiki/Documentation/DockerYoctoBuild for details. When using a Docker container, it does not matter what Linux distribution or packages you have installed on your host, as all dependencies are provided by the Docker container.
In addition to the above, you must also install python3-newt, and python3.10-venv with a command like this:
Set up Environment
Create a top folder for this example, as the rest of the commands assume this location:
Enable Quartus tools to be called from command line:
Build Quartus Design
Use the following commands to build the Quartus Design:
cd $TOP_FOLDER
rm -rf dk-dev-agm039fes-oobe-baseline
mkdir dk-dev-agm039fes-oobe-baseline
cd dk-dev-agm039fes-oobe-baseline
wget https://github.com/altera-fpga/agilex7-ed-hps-baseline/releases/download/QPDS26.3_REL_BASELINE_PR/dk-dev-agm039fes-oobe-baseline.zip
unzip dk-dev-agm039fes-oobe-baseline.zip
rm -f dk-dev-agm039fes-oobe-baseline.zip
make baseline-install
The following files are created:
$TOP_FOLDER/dk-dev-agm039fes-oobe-baseline/install/binaries/baseline.sof- FPGA configuration file, without HPS FSBL$TOP_FOLDER/dk-dev-agm039fes-oobe-baseline/install/binaries/ghrd.core.rbf- FPGA fabric configuration file
Build Yocto Using Kas
1. Create and enter a new Python virtual environment:
cd $TOP_FOLDER/dk-dev-agm039fes-oobe-baseline/software/yocto_linux
python3 -m venv venv --system-site-packages
source venv/bin/activate
pip install --upgrade pip
pip install kas
pip install --upgrade kas
pip install kconfiglib
2. Copy the core.rbf file to where Kas expects it to be:
cp $TOP_FOLDER/dk-dev-agm039fes-oobe-baseline/install/binaries/ghrd.core.rbf meta-custom/recipes-fpga/fpga-bitstream/files/baseline_hps_debug.core.rbf
3. Build Yocto with Kas:
The following relevant files are created in $TOP_FOLDER/dk-dev-agm039fes-oobe-baseline/software/yocto_linux/build/tmp/deploy/images/agilex7m/:
gsrd-console-image-agilex7m.rootfs.wicu-boot-spl-dtb.hex
Note: If you experience build failures related to file-locks, you can work around these by reducing the parallelism of your build by running the following commands before running
kas:
export PARALLEL_MAKE="-j 8"
export BB_NUMBER_THREADS="8"
export BB_ENV_PASSTHROUGH_ADDITIONS="$BB_ENV_PASSTHROUGH_ADDITIONS PARALLEL_MAKE BB_NUMBER_THREADS"
Create Bootable HPS RBF File
cd $TOP_FOLDER
rm -f *rbf*
quartus_pfg -c $TOP_FOLDER/dk-dev-agm039fes-oobe-baseline/install/binaries/baseline.sof \
 ghrd.rbf \
 -o hps_path=$TOP_FOLDER/dk-dev-agm039fes-oobe-baseline/software/yocto_linux/build/tmp/deploy/images/agilex7m/u-boot-spl-dtb.hex \
 -o hps=1
The following files will be created:
- $TOP_FOLDER/ghrd.hps.rbf - RBF file to configure the device for HPS first, phase 1
How to Manually Update the kernel.itb file
The kernel.itb file is a Flattattened Image Tree (FIT) file that includes the following components:
- Linux kernel.
- Board configurations* that indicate what components from the kernel.itb (Linux kernel, device tree and Phase 2 FPGA configuration bitstream) should be used for a specific board.
- Linux device tree*.
- Phase 2 FPGA configuration bitstream*.
* One or more of these components to support the different board configurations.
The kernel.itb is created from a .its (Image Tree Source file) that describes its structure. In the HPS Baseline System Example Design, the kernel.itb file is generated in the following directory. In this directory you can also find the .its files and all other the components needed to create the kernel.itb :
- $TOP_FOLDER/<gsrd-directory>/<project-directory>/software/yocto_linux/build/tmp*/work/<device>-poky-linux/linux-socfpga-lts/<linux-branch>+git/linux-<device>-standard-build/
As an example of this path, for the Agilex 5 device you will find this directory as $TOP_FOLDER/a5ed065es-premium-devkit-oobe/baseline-a55/software/yocto_linux/build/tmp*/work/agilex5e-poky-linux/linux-socfpga-lts/6.12.43-lts+git/linux-agilex5e-standard-build
If you want to modify the kernel.itb by replacing one of the component or modifying any board configuration, you can do the following:
-
Install mtools package in your Linux machine.
-
Go to the folder in which the kernel.itb is being created under the HPS Baseline System Example Design.
-
In the .its file, observe the components that integrates the kernel.itb identifying the nodes as indicated next:
images node:
- kernel node - Linux kernel defined with the data parameter in the node.
- fdt-X node - Device tree X defined with the data parameter in the node.
- fpga-X node - Phase 2 FPGA configuration bitstream .rbf defined with the data parameter in the node.configurations node:
- board-X node - Board configuration with the name defined with the description parameter. The components for a specific board configuration are defined with the kernel, fdt and fpga parameters. -
In this directory, you can replace any of the file components that integrate the kernel.itb, or you can also modify the .its to change the structure and components of the kernel.itb.
-
Finally, you need to re-generate the new kernel.itb running the following command in the same linux-
-standard-build/ directory.
Once that you have completed this procedure, you can use the new kernel.itb as needed. Some options could be:
- Use U-Boot to load this into the SDRAM board through TFTP to boot Linux or to write it to a flash device
- Directly update the flash image in your board (QSPI, SD Card, eMMC or NAND) from your working machine.
How to Manually Update the SD Card Content file
As part of the Yocto HPS Baseline System Example Designbuild flow, the SD Card image is built for the SD Card boot flow. This image includes a couple of partitions. One of these partition (a FAT32) includes the U-Boot proper, the Distroboot boot script, U-Boot environment and the Linux .itb - which includes the Linux kernel image, the Linux device tree, the phase 2 FPGA configuration bitstream and board configuration (there may be several versions of these last 3 components). The 2nd partition (an EXT3 or EXT4 ) includes the Linux file system.
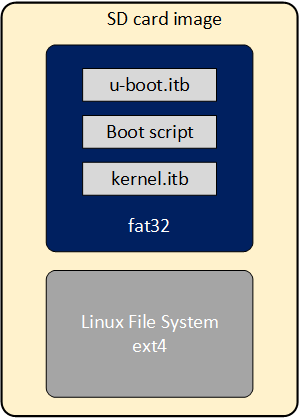
If you want to replace any the components or add a new item in any of these partitions, without having to run again the Yocto build flow.
This can be done through the wic script available on the Poky repository that is included as part of the HPS Baseline System Example Design build directory:
- $TOP_FOLDER/<gsrd-directory>/<project-directory>/software/yocto_linux/poky/scripts/wic
The wic command requires to be run in the Yocto build environment that can be setup as shown next in a Linux terminal:
cd $TOP_FOLDER/<gsrd-directory>/<project-directory>/software/yocto_linux/
source poky/oe-init-build-env build
The wic command allows you to inspect the content of a SD Card image, delete, add or replace any component inside of the image. This command is also provided with help support:
$ $TOP_FOLDER/<gsrd-directory>/<project-directory>/software/yocto_linux/poky/scripts/wic help

Creates a customized OpenEmbedded image.

Usage:  wic [--version]
        wic help [COMMAND or TOPIC]
        wic COMMAND [ARGS]

    usage 1: Returns the current version of Wic
    usage 2: Returns detailed help for a COMMAND or TOPIC
    usage 3: Executes COMMAND

COMMAND:

 list   -   List available canned images and source plugins
 ls     -   List contents of partitioned image or partition
 rm     -   Remove files or directories from the vfat or ext* partitions
 help   -   Show help for a wic COMMAND or TOPIC
 write  -   Write an image to a device
 cp     -   Copy files and directories to the vfat or ext* partitions
 create -   Create a new OpenEmbedded image
 :
 :
The following steps show you how to replace the kernel.itb file inside of the fat32 partition in a .wic image.
-
The wic ls command allows you to inspect or navigate over the directory structure inside of the SD Card image. For example you can observe the partitions in the SD Card image in this way.
# Here you can inspect the content a wic image see the 2 partitions inside of the SD Card image $ $TOP_FOLDER/<gsrd-directory>/<project-directory>/software/yocto_linux/poky/scripts/wic ls my_image.wic Num Start End Size Fstype 1 1048576 525336575 524288000 fat32 2 525336576 2098200575 1572864000 ext4 # Here you can naviagate inside of the partition 1 $ $TOP_FOLDER/<gsrd-directory>/<project-directory>/software/yocto_linux/poky/scripts/wic ls my_image.wic:1 Volume in drive : is boot Volume Serial Number is 8F65-ACE9 Directory for ::/ BOOTSC~1 UIM 2739 2011-04-05 23:00 boot.scr.uimg kernel itb 12885831 2011-04-05 23:00 uboot env 8192 2011-04-05 23:00 u-boot itb 938816 2011-04-05 23:00 4 files 13 835 578 bytes 509 370 368 bytes free -
The wic rm command allows you to delete any of the components in the selected partition. For example, you can delete the kernel.itb image from the partition 1(fat32 partition).
-
The wic cp command allows you to copy any new item or file from your Linux machine to a specific partition and location inside of the SD Card image. For example, you can copy a new kernel.itb to the partition 1.
NOTE: The wic application also allows you to modify any image with compatible vfat and ext* type partitions which also covers images used for eMMC boot flow.
Configure Through AVSTx8
This section presents the details on how the GSRD can be configured automatically at power up through AVSTx8, instead of using JTAG.
The required steps are:
1. Create the PFG file 2. Create the POF file, using the above PFG file 3. Create the CDF file, used by Quartus Programmer to know how to write the POF file 4. Write the the POF file to MAX10 board controller flash, using the Quartus Programmer 5. Configure board through AVSTx8
Warning: When using the AVSTx8 configuration method on the DevKit, the 'reboot' command from U-Boot and Linux will not work. This is because the 'reboot' command issues a Cold Reset to HPS, resulting in SDM wiping HPS and waiting for the configuration bitstream to be re-sent through AVSTx8 which is not implemented on this board. In order to make this work you need to inform the external configuration agent to re-send the configuration bitstream once the Cold Reset happens.
Create Programmer Generator Configuration for AVSTx8
The PFG file contains information needed by the Quartus Programming File Generator to create the POF file to be stored on the QSPI flash attached to the MAX 10 board controller. The MAX 10 board controller reads the information from that QSPI file and configures the FPGA device over AVST.
This section provides the details on how the PFG file is created. The steps required to create the file are:
1. Start Programmer File Generator GUI:
2. In the Output Files tab:
- Select Device family: Agilex™ 7
- Select Configuration mode: AVSTx8
- Edit Name: ghrd_agmf039r47a1e2vr0
- Check Programmer Object File (.pof)
- Check Memory Map File (.map)
The window will look similar to this:
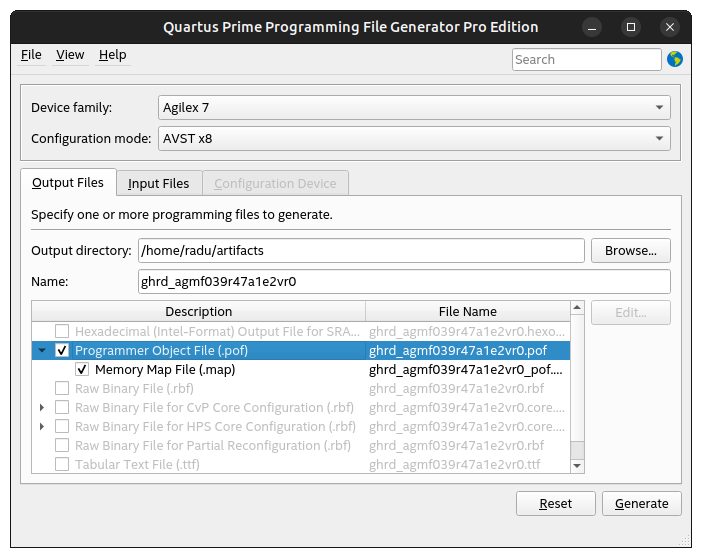
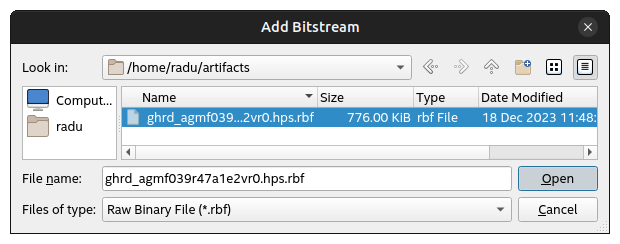
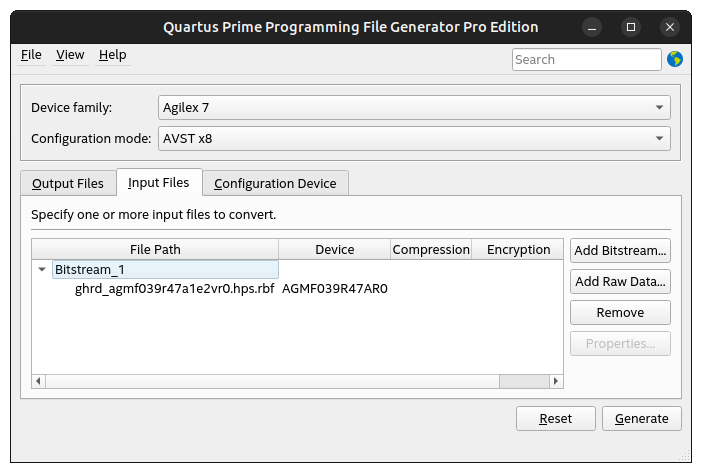
3. Click on the Input Files tab, then click on Add Bitstream... , then select Files of type to be "Raw Binary File (.rbf)" then browse to the ghrd.hps.rbf file and click **Open*.
The window will look similar to this:
4. Go to Configuration Device tab, click Add Device, select the CFI_2Gb option and click OK.
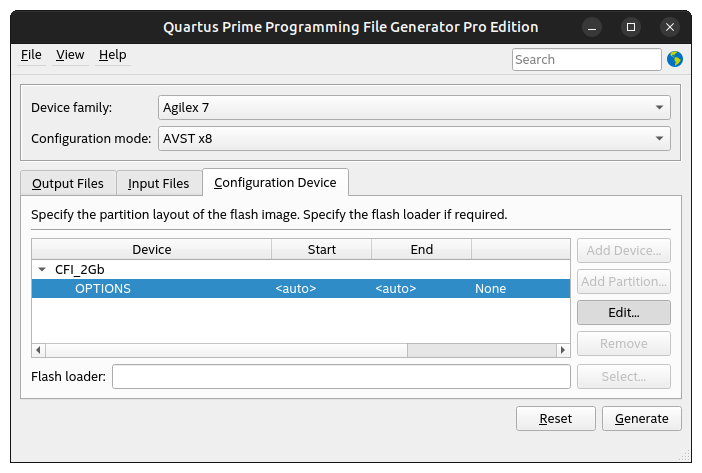
5. Click on the OPTIONS partition to select it, then click the Edit button:
6. In the Edit Partition window, select the following:
- Address Mode: Start
- Start Address: 0x00002000
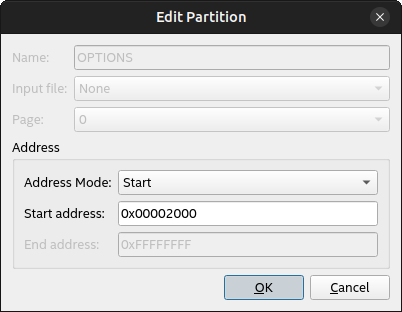
Press OK.
7. Click on CFI_2Gb then click Add Partition and select the following:
- Name: P1
- Input file: Bitstream_1
- Address mode: Start
- Start address: 0x00004000
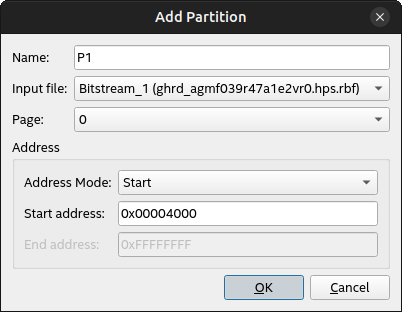
Press OK.
8. Go to File > Save menu and save the configuration file as "ghrd.pfg"
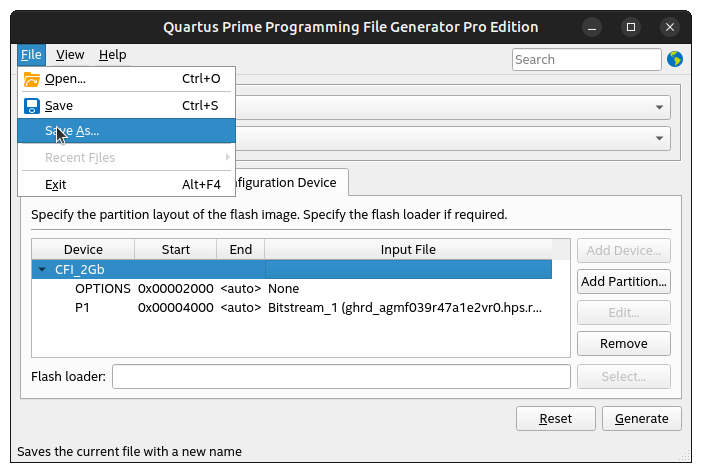
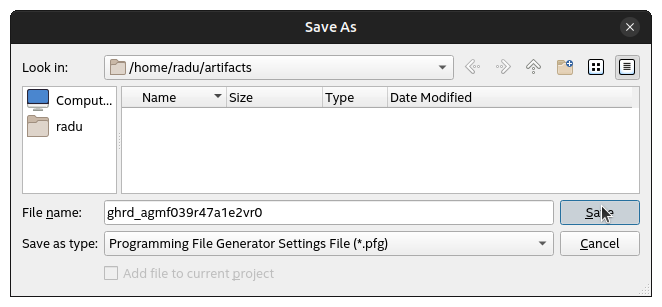
Note: The created PFG file contains absolute paths. The attached PFG file was manually edited to use relative paths instead, so it can be used even when moving files in other folders on the host PC.
9. At this point you can generate the POF directly by clicking the Generate button.
Caution: Please use the addresses 0x00002000 for OPTIONS and 0x00004000 for P1, as they are required by the MAX10 board controller.
Create POF AVSTx8 Configuration File
The POF file is created by using the PFG file and running the following command:
The following file is created:
$TOP_FOLDER/ghrd.pof- contains the MAX 10 flash image required to configure the Agilex™ 7 device over AVST
Create CDF Programmer Configuration File
This section provides instructions on how to create the configuration file required for the Quartus Programmer to be able to write the POF file to the QSPI attached to the MAX 10 Board Controller.
1. Set dipswitch S24 to OFF-OFF-OFF-ON so that board configures through JTAG.
2. Power up the board
3. Start Programmer GUI:
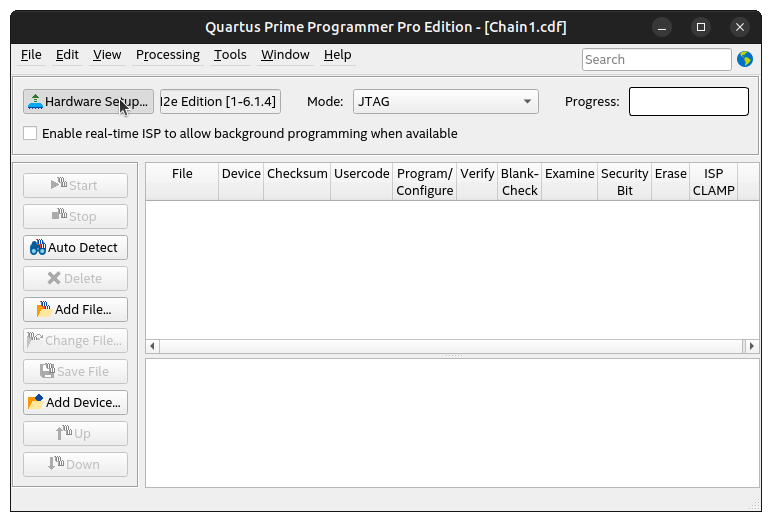
4. In the Programmer window, click on Hardware Setup and select the following:
- Currently selected hardware: Intel Agilex™ M-Series Development Kit - HBM2e Edition
- Hardware Frequency: 16000000
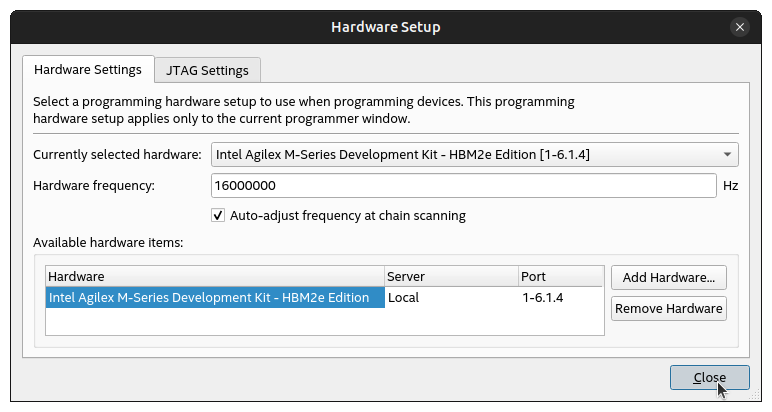
Then click Close.
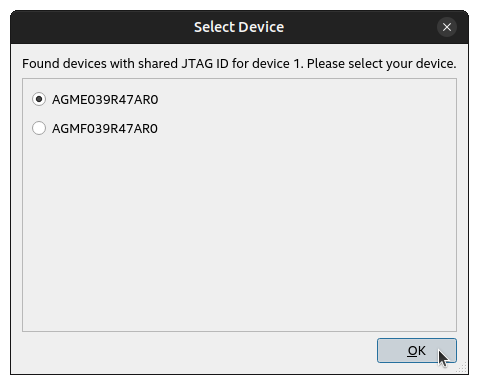
5. In the Programmer window click Autodetect, then select either option from the Select Device window as shown below:
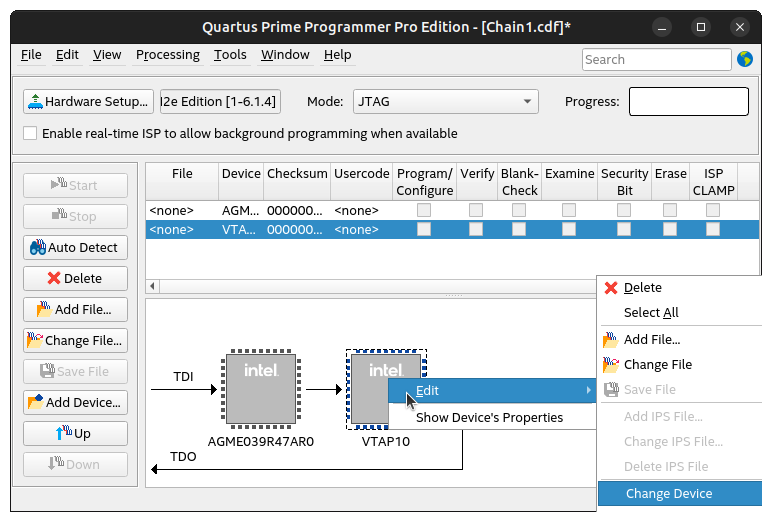
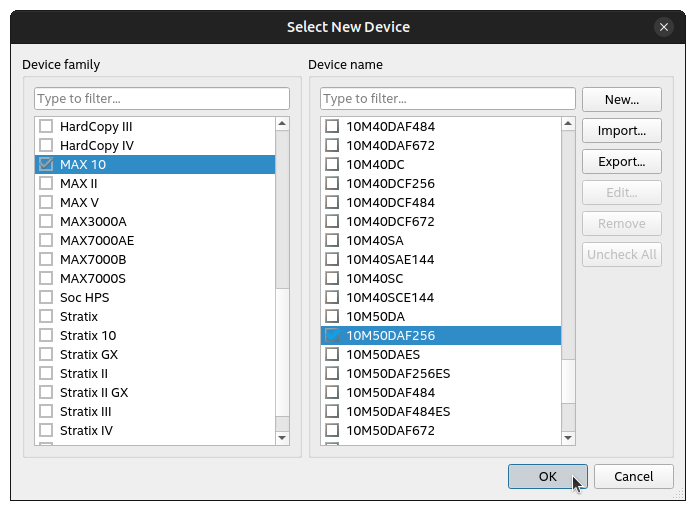
6. In the Programmer window, select the VTAP10 device, then right-click it, and select Edit > Change Device
Select the MAX 10 > 10M50DAF256 device then click OK.
7. Right click the MAX10 device, and select Edit > Attach Flash Device
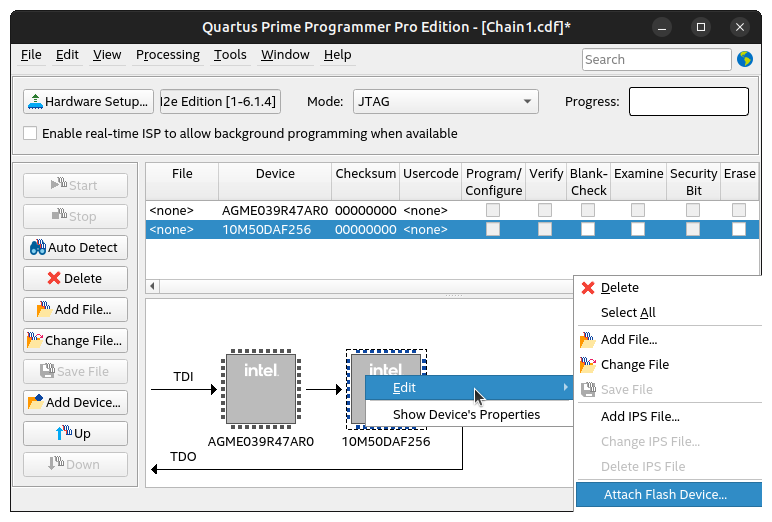
Select Quad SPI Flash Memory > QSPI_2Gb option and click OK
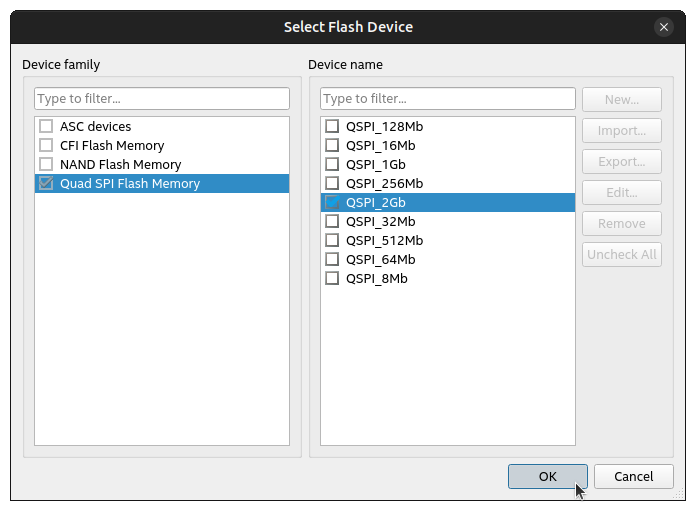
8. Right click the QSPI_2Gb entry on the top panel, then click Change File
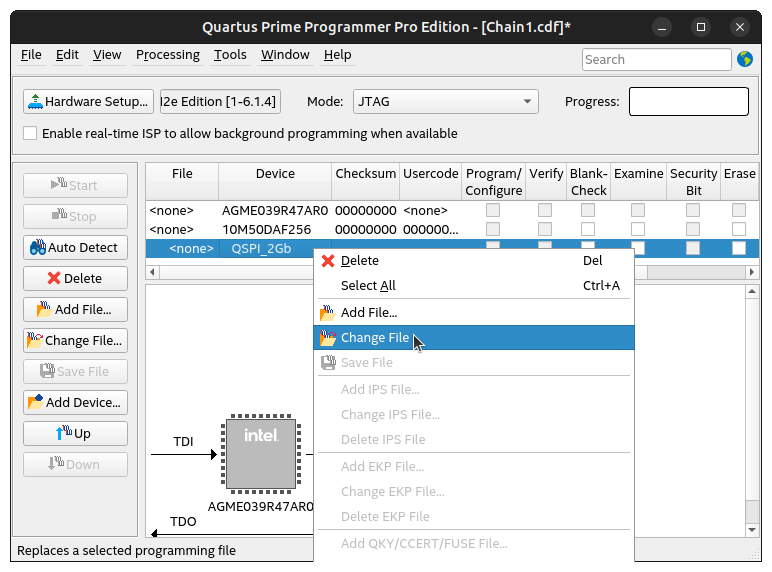
Browse to "ghrd_agmf039r47a1e2vr0.pof" and click Open.
9. In the Programmer window, select the Program/Configure and Verify checkboxes for both "P1" and "OPTION_BITS" partitions
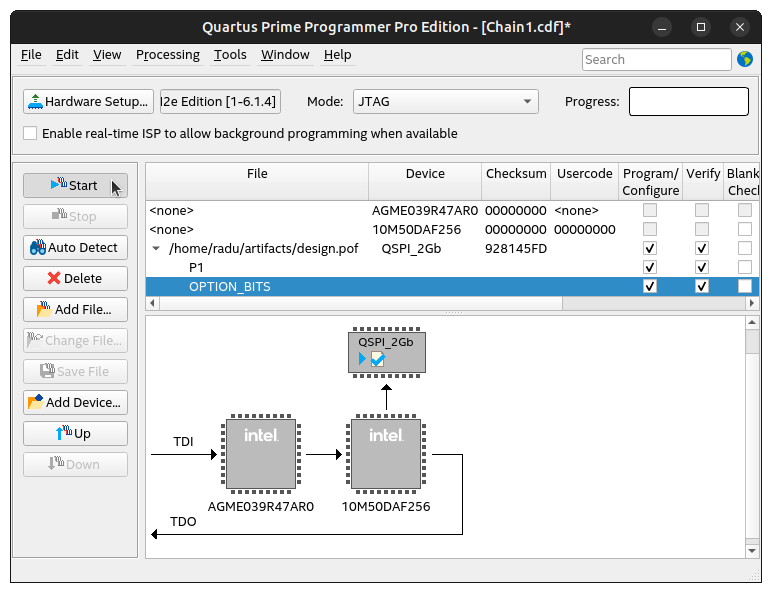
10. Go to File > Save and save the configuration file as "board.cdf"
Note: The output file "ghrd.cdf" has an absolute path to the "ghrd.pof" file. You can hand edit it to use a relative path instead, so files could be located anywhere on the host PC file system.
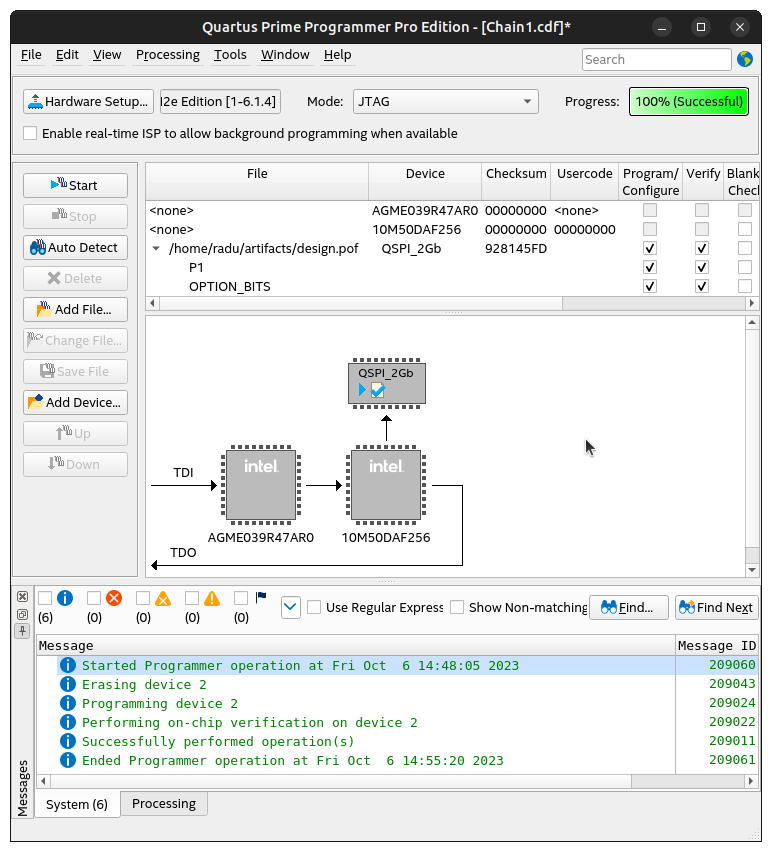
11. At this stage you can also click the Start button, for the Programmer to write the file to flash. A progress bar will be shown:
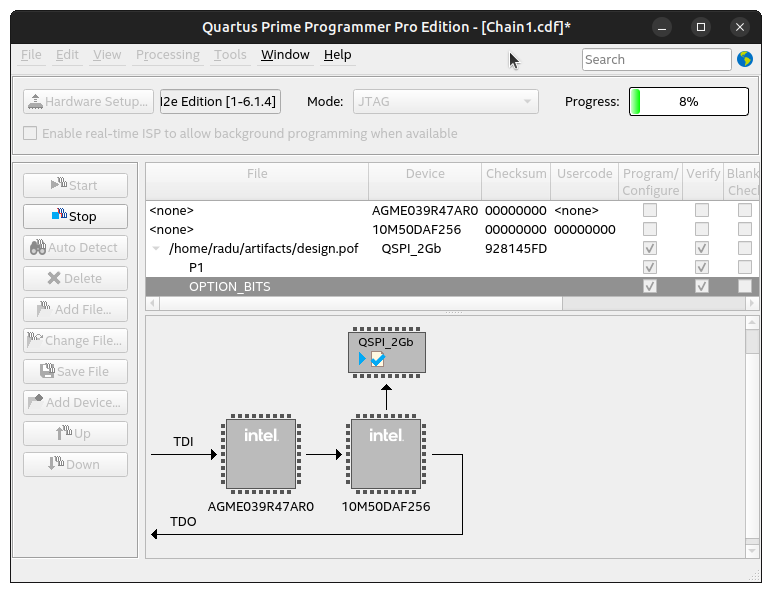
12. On successfull completion, the Programmer will show 100% completed:
Write POF File Using the CDF File
1. Connect the following cables to the board:
- Power: from board to power supply
- JTAG: from micro USB cable on edge of the board to host PC
2. Configure board to the default settings, except set S24 dipswitch to OFF-OFF-OFF-ON, to select MSEL=JTAG, so that board does not configure on power up.
3. Power up the board
4. Make sure you have the following files in the current folder:
- ghrd.cdf
- ghrd.pof
5. Run the following command to flash the POF file:
Boot Linux
1. Power down the board
2. Set S24 to ON-OFF-OFF-ON to set MSEL=AVSTx8, so that the FPGA device gets configured with the POF on the next power cycle.
3. Power up the board
4. FPGA device will get configured, the U-Boot SPL will be ran, then U-Boot and then Linux. Log in with 'root' when prompted, no passowrd will be required, just like when configuring board with the RBF file.
Notices & Disclaimers
Altera® Corporation technologies may require enabled hardware, software or service activation. No product or component can be absolutely secure. Performance varies by use, configuration and other factors. Your costs and results may vary. You may not use or facilitate the use of this document in connection with any infringement or other legal analysis concerning Altera or Intel products described herein. You agree to grant Altera Corporation a non-exclusive, royalty-free license to any patent claim thereafter drafted which includes subject matter disclosed herein. No license (express or implied, by estoppel or otherwise) to any intellectual property rights is granted by this document, with the sole exception that you may publish an unmodified copy. You may create software implementations based on this document and in compliance with the foregoing that are intended to execute on the Altera or Intel product(s) referenced in this document. No rights are granted to create modifications or derivatives of this document. The products described may contain design defects or errors known as errata which may cause the product to deviate from published specifications. Current characterized errata are available on request. Altera disclaims all express and implied warranties, including without limitation, the implied warranties of merchantability, fitness for a particular purpose, and non-infringement, as well as any warranty arising from course of performance, course of dealing, or usage in trade. You are responsible for safety of the overall system, including compliance with applicable safety-related requirements or standards. © Altera Corporation. Altera, the Altera logo, and other Altera marks are trademarks of Altera Corporation. Other names and brands may be claimed as the property of others.
OpenCL* and the OpenCL* logo are trademarks of Apple Inc. used by permission of the Khronos Group™.